
 3차원 좌표의 회전
x, y, z축을 중심으로 좌표를 회전했을 때의 새로운 좌표를 계산합니다.
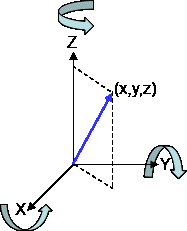
| \(\normalsize Rotation\ of\ points\hspace{20px}\theta: (x,y,z)\rightarrow (x',y',z')\\ \begin{pmatrix} x'\\ y'\\ z'\\ \end{pmatrix}_{x} = \begin{pmatrix} 1 & 0 & 0 \\ 0 & \cos\theta & -\sin\theta \\ 0 & \sin\theta & \cos\theta \end{pmatrix} \begin{pmatrix} x\\ y\\ z\\ \end{pmatrix} \\ \begin{pmatrix} x'\\ y'\\ z'\\ \end{pmatrix}_{y} = \begin{pmatrix} \cos\theta & 0 & \sin\theta \\ 0 & 1 & 0 \\ -\sin\theta & 0 & \cos\theta \end{pmatrix} \begin{pmatrix} x\\ y\\ z\\ \end{pmatrix} \\ \begin{pmatrix} x'\\ y'\\ z'\\ \end{pmatrix}_{z} = \begin{pmatrix} \cos\theta & -\sin\theta & 0 \\ \sin\theta & \cos\theta & 0 \\ 0 & 0 & 1 \end{pmatrix} \begin{pmatrix} x\\ y\\ z\\ \end{pmatrix} \) |
이 계산에 대한 고객 피드백이 아직 없습니다.